취업게시끈
[박사후연구원 채용 공고] ITER 국제기구 - Remote Handling (로봇 및 기계 분야) | 2026년 3월 1일까지 접수
포항공과대학교
익명의 끈2026. 02. 17. 17:06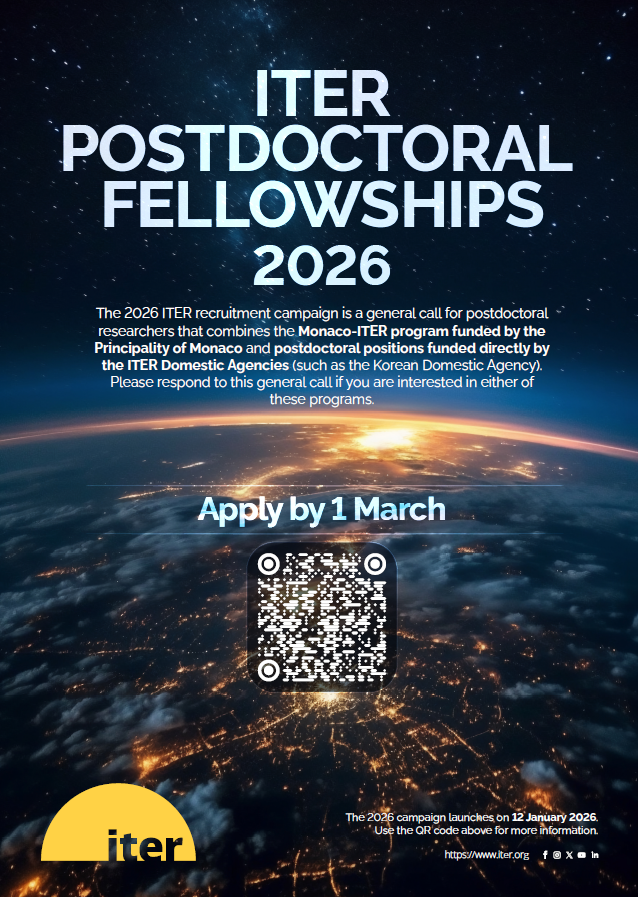
기업명: ITER Organization (국제기구)
기업 홈페이지: www.iter.org
채용 공고 제목: 2026 ITER Postdoctoral Fellowships
채용 공고 링크 및 지원 방법: https://www.iter.org/public/education/international/monaco/iter-and-iter-postdoctoral-fellowships
업·직종: Engineer
근무형태: 계약직
학력제한: 박사 (로봇, 기계)
모집인원: 0 명
연봉: 세전 약 90,000 Euros (P1-5, Korean PostDoc의 경우)
채용직급/직책: Postdoctor
근무지역: St Paul Lez Durance, France
모집 기간 : 2 years
Topic 16) Automated component handling
The Remote Handling Project in ITER has been developing handling equipment and tools to carry out the initial assembly of the in-vessel components in the ITER Tokamak. One of the main assembly systems is called the Blanket Assembly Transporter (BAT), and it is used to install the ITER blanket modules inside the vacuum vessel (VV).
The BAT is a long reach bespoke robotic arm and the blanket modules weigh between 1.4 and 4 tons. The Blanket modules need to be picked up and installed in precise locations on the vacuum vessel walls as an automated operation. There are many variations in shape, size, and location of the modules that make this a very challenging task. The BAT will use a vision system to achieve accurate positioning within the VV and a six degree of freedom force-moment sensor to manage forces through the engagement of components and transferring of loads between the robot and the VV wall. A sophisticated control algorithm needs to be developed to interpret the force-moment measurements and adapt the motions of the BAT in order to install/remove modules as an automated function. The algorithm will have to deal with multiple contact points during the operation and resolve the correct motion to reliably complete the task without damaging the equipment or environment. The development work will take place using an industrial robot with 2 ton capacity and mock-ups of the components and VV. The objective is to develop the methodology and control algorithms that successfully perform the tasks and can then be ported to the BAT.
An additional aspect is the modelling of the deflections of the BAT through the process of the load transfer operation in order to be able to remotely monitor that the performance of the system remains within operational limits.
Qualifications/ Expertise Required
▪ Experience in robotic system design/analysis & control theory
▪ Experience in MATLAB/SIMULINK, Python, C/C++
▪ Experience in 3D CAD & robot simulator and programming as advantage
관심있는 주위 박사분들께 전달 부탁드립니다.
한국핵융합연구원에 문의하셔도 자세히 알려주실거예요.
기업 홈페이지: www.iter.org
채용 공고 제목: 2026 ITER Postdoctoral Fellowships
채용 공고 링크 및 지원 방법: https://www.iter.org/public/education/international/monaco/iter-and-iter-postdoctoral-fellowships
업·직종: Engineer
근무형태: 계약직
학력제한: 박사 (로봇, 기계)
모집인원: 0 명
연봉: 세전 약 90,000 Euros (P1-5, Korean PostDoc의 경우)
채용직급/직책: Postdoctor
근무지역: St Paul Lez Durance, France
모집 기간 : 2 years
Topic 16) Automated component handling
The Remote Handling Project in ITER has been developing handling equipment and tools to carry out the initial assembly of the in-vessel components in the ITER Tokamak. One of the main assembly systems is called the Blanket Assembly Transporter (BAT), and it is used to install the ITER blanket modules inside the vacuum vessel (VV).
The BAT is a long reach bespoke robotic arm and the blanket modules weigh between 1.4 and 4 tons. The Blanket modules need to be picked up and installed in precise locations on the vacuum vessel walls as an automated operation. There are many variations in shape, size, and location of the modules that make this a very challenging task. The BAT will use a vision system to achieve accurate positioning within the VV and a six degree of freedom force-moment sensor to manage forces through the engagement of components and transferring of loads between the robot and the VV wall. A sophisticated control algorithm needs to be developed to interpret the force-moment measurements and adapt the motions of the BAT in order to install/remove modules as an automated function. The algorithm will have to deal with multiple contact points during the operation and resolve the correct motion to reliably complete the task without damaging the equipment or environment. The development work will take place using an industrial robot with 2 ton capacity and mock-ups of the components and VV. The objective is to develop the methodology and control algorithms that successfully perform the tasks and can then be ported to the BAT.
An additional aspect is the modelling of the deflections of the BAT through the process of the load transfer operation in order to be able to remotely monitor that the performance of the system remains within operational limits.
Qualifications/ Expertise Required
▪ Experience in robotic system design/analysis & control theory
▪ Experience in MATLAB/SIMULINK, Python, C/C++
▪ Experience in 3D CAD & robot simulator and programming as advantage
관심있는 주위 박사분들께 전달 부탁드립니다.
한국핵융합연구원에 문의하셔도 자세히 알려주실거예요.
링크가 복사되었습니다!